The Humanoid Hub presents
HUMANOID HUB CONFERENCE

The best in robotics and embodied AI, together for two days of demos, keynotes, and panel discussions.
October 15-16, 2026 | AWS Builder Loft, San Francisco
- Robot Demos
- Companies on the floor
- 800
- Seats
- Talks & panels
- 2 days
- October 15-16
Sponsors & Exhibitors



Confirmed speakers
Speakers
Tap a card (or hover) to read the bio.
-
 Eric Jang
Eric Jang spent four years as VP of AI at 1X Technologies, joining as its first California hire and building the AI team behind NEO: whole-body RL controllers, VLAs, world models, simulation, and the data engine. Before 1X he was a research scientist at Google Brain, where he co-authored the Gumbel-Softmax paper. He writes at evjang.com.
-
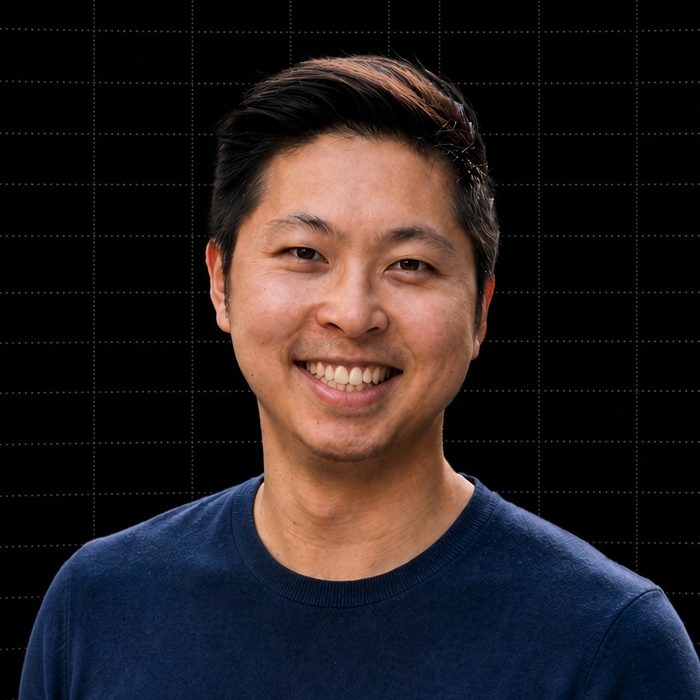 Ted Xiao
Ted Xiao spent eight years at Google DeepMind, most recently as a staff research scientist and tech lead across Gemini Robotics and Gemini Multimodal. He co-created the line of work that brought foundation models into robot control: SayCan, RT-1, RT-2, and Open X-Embodiment. He is now a founding member of technical staff at Prometheus, building AGI for the physical economy.
-
 Deepak Pathak
Deepak Pathak is co-founder and CEO of Skild AI, building a general-purpose brain that transfers across robot embodiments. He is also an associate professor at Carnegie Mellon, where the company started. He previously did research at Meta's FAIR. His work on curiosity-driven exploration and rapid motor adaptation underpins much of modern robot learning.
-
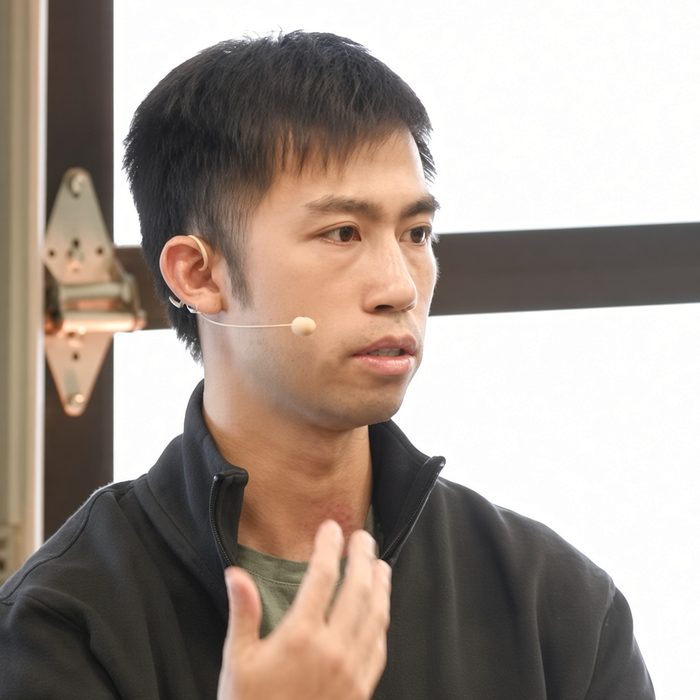 Jason Ma
Jason Ma is co-founder of Dyna Robotics. He earned his PhD at UPenn's GRASP Lab, where his research reshaped how robots learn rewards and representations: the VIP and LIV methods, and Eureka, which had language models write reward functions that beat human-designed ones. He previously worked in NVIDIA's robotics research group.
-
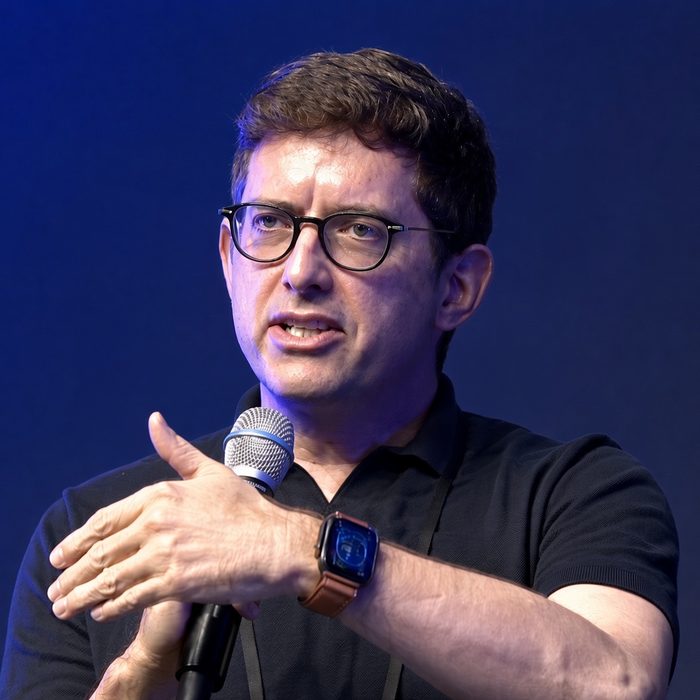 Jan Liphardt
Jan Liphardt is the founder of OpenMind, which is building OM1, an open, hardware-agnostic operating system that aims to be the 'Android for robots.' He is an associate professor of bioengineering at Stanford, and previously taught at UC Berkeley. His research spans biophysics, computational genomics, and decentralized trust systems for machines.
-
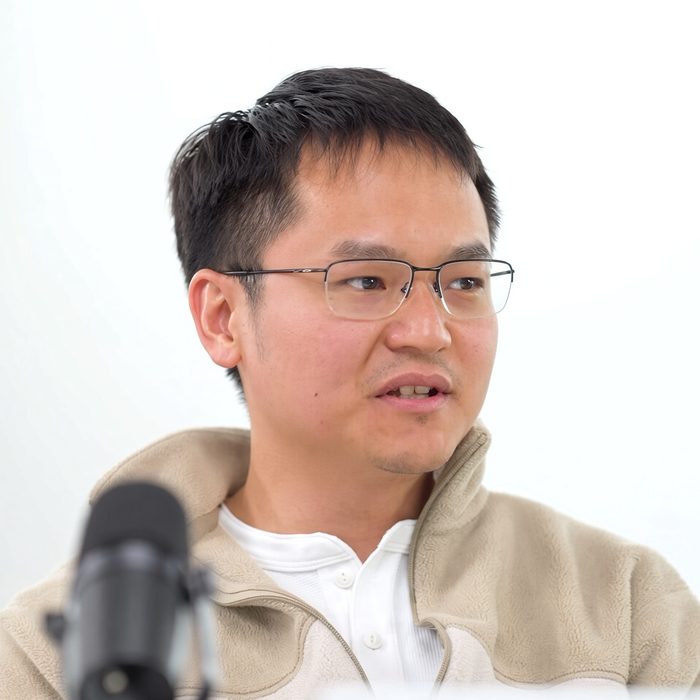 Quan Vuong
Quan Vuong is a co-founder of Physical Intelligence, the startup building general-purpose foundation models that let a single AI control many different robots. Before that he was a researcher at Google DeepMind, where he helped create the vision-language-action models behind modern robot control, including RT-2 and the open-source OpenVLA.
-
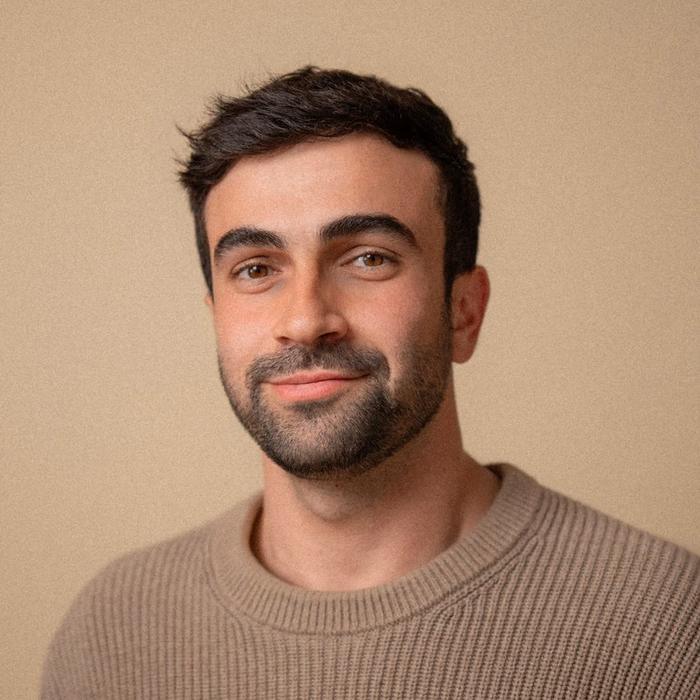 Dar Sleeper
Dar Sleeper is the Chief Designer at 1X, where he designed NEO, the company's home humanoid. He joined as 1X's first non-engineering hire, after leading product at Tesla where he helped launch the Cybertruck. He threw out the chrome-and-LED visual language of science fiction, arguing that a machine built to live in your house should feel familiar rather than futuristic. His studio designs everything in house, from the robot to its clothing and furniture.
-
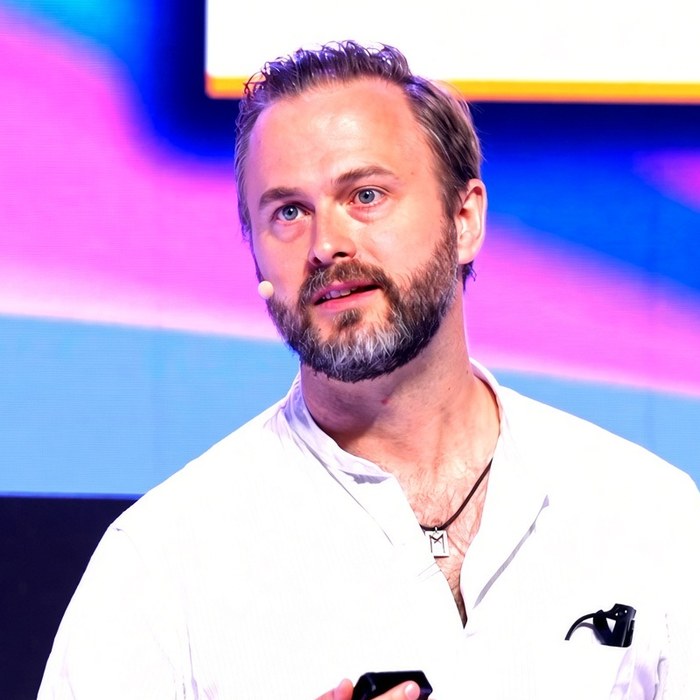 Nils Pihl
Nils Pihl is the founder and CEO of Auki Labs, which is building the posemesh, a decentralized protocol that gives humans, robots and AI agents a shared understanding of physical space. Its flagship product, Cactus, combines digital twins, computer vision and autonomous robotics to coordinate human and robotic staff in real environments. The underlying bet is that foundation models need grounding in physical context to be useful, and that no single company should own the map of the world's private spaces.